Researchers Create Energy-Efficient Drone That Launches Like a Crow.

Gallery
Videos
Researchers at the École Polytechnique Fédérale de Lausanne (EPFL) have unveiled a groundbreaking bird-inspired drone named RAVEN, capable of walking, hopping, and jumping to initiate flight without the need for a runway, launcher, or human assistance.
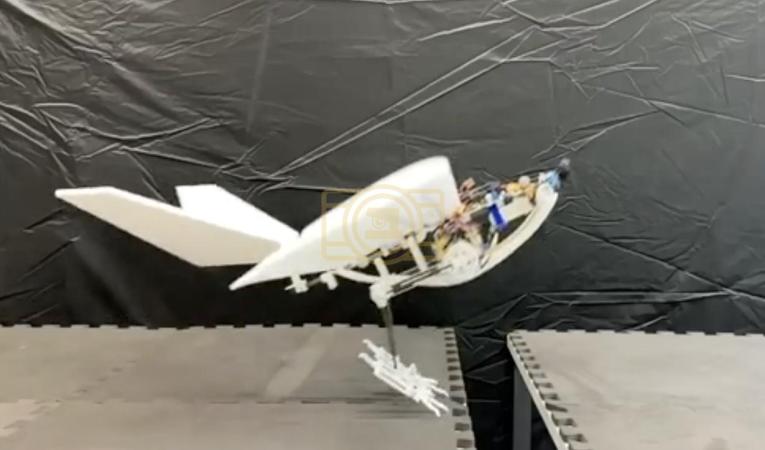
Unlike conventional drones that treat legs as passive or dead weight, the EPFL team designed lightweight avian legs that actively contribute to locomotion and takeoff. Inspired by the anatomy of crows and ravens, these spring-motor legs store and release energy via flexible toes and tendon-like springs, enabling efficient movement across complex terrain.
The RAVEN drone demonstrates remarkable agility: it can walk at 0.25 meters per second, jump up to 26 centimeters, hop over gaps exceeding 12 centimeters, and take off to nearly 50 centimeters in height at a forward speed of 2.2 meters per second. Compared to static or conventional runway launches, this method is ten times more energy-efficient, allowing for rapid deployment in environments where traditional takeoff methods are impossible.
The drone’s 1-meter wingspan complements its leg-driven locomotion, allowing a seamless transition from hopping and walking to fixed-wing flight. Sequential frames from the research video illustrate RAVEN navigating rough terrain, leaping onto elevated platforms, and efficiently launching into the air — all autonomously.
EPFL’s RAVEN represents a major advance in bio-inspired robotics, integrating mechanical efficiency with practical adaptability. By mimicking the energy-efficient leg mechanics of birds, the design not only reduces the energy cost of takeoff but also enables drones to operate in confined, complex, or unpredictable environments where traditional flight systems cannot function effectively.
This innovation opens new possibilities for autonomous drones in search-and-rescue operations, environmental monitoring, and other applications where navigating uneven terrain or launching without runways is critical. The RAVEN drone exemplifies how inspiration from nature can transform robotic design, combining agility, efficiency, and versatility in a single platform.