Loading
זעמל - Kerestir: The grandchildren who run the Hachnasas Orchim at Reb Yeshayale's house distributing dollars on Motzaei Yom Kippur to the guests who spen..   |  זעמל - Williamsburg: The Satmar Rebbe's Shulchan Hatahor on Motzaei Yom Kippur After Spending Yom Tov in the City.   |  זעמל - Kiryat Gat - During construction excavations for the new Carmei Gat neighborhood, archaeologists have unearthed a 2,000-year-old mikvah taharah.   |  אידישער ווינקל - A video from the Russian-occupied Crimean Peninsula shows local Jewish residents performing the minhag of Kapparos on Erev Yom Kippur using a large fish.   |  אידישער ווינקל - Mix-Up: Australian F-35 Fighter Jet Parts Mistakenly Sent to Hong Kong   |  בקיצור - Trump Administration Pledges $410 Million to 31 Countries to Accept Deported Immigrants   |  בקיצור - Kamala Harris Undecided on 2028 Presidential Run, Though Allies Doubt She Will Enter the Race   |   זעמל - Kerestir: The grandchildren who run the Hachnasas Orchim at Reb Yeshayale's house distributing dollars on Motzaei Yom Kippur to the guests who spen..   |  זעמל - Williamsburg: The Satmar Rebbe's Shulchan Hatahor on Motzaei Yom Kippur After Spending Yom Tov in the City.   |  זעמל - Kiryat Gat - During construction excavations for the new Carmei Gat neighborhood, archaeologists have unearthed a 2,000-year-old mikvah taharah.   |  אידישער ווינקל - A video from the Russian-occupied Crimean Peninsula shows local Jewish residents performing the minhag of Kapparos on Erev Yom Kippur using a large fish.   |  אידישער ווינקל - Mix-Up: Australian F-35 Fighter Jet Parts Mistakenly Sent to Hong Kong   |  בקיצור - Trump Administration Pledges $410 Million to 31 Countries to Accept Deported Immigrants   |  בקיצור - Kamala Harris Undecided on 2028 Presidential Run, Though Allies Doubt She Will Enter the Race   |  

NO LEGS, NO WHEELS: Robot Hand Crawls Using Only Its Fingers
September 17th,

0 269
Main image for NO LEGS, NO WHEELS: Robot Hand Crawls Using Only Its Fingers

Videos


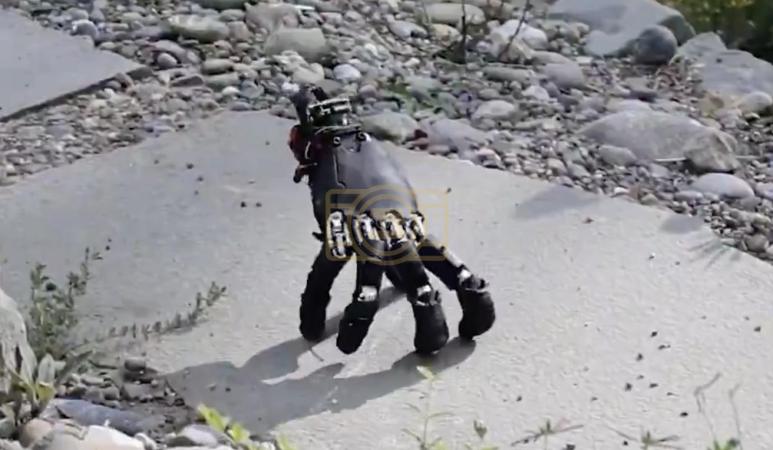
Researchers at ETH Zürich have built something straight out of a horror movie: a robotic hand that crawls across surfaces on its own fingers, with no wheels, no legs, and no separate drive system bolted underneath. The same fingers designed to grasp objects also bear the hand's full weight and carry it across the ground, essentially turning a grasping tool into its own means of transportation. The team did not build a special-purpose machine for this trick either. They kept the hand's existing finger design and position controller exactly as they were, then wrote an entirely new reward formulation suited to a hand's unique geometry, since standard quadruped locomotion research assumes four evenly spaced, identical legs, a layout that looks nothing like a palm with unevenly spaced fingers and a thumb that matches none of them.

That custom approach paid off, letting the hand move faster in simulation than it did using reward functions borrowed straight from quadruped robots. In testing, the hand crawls, steers, and even recovers on its own after being knocked over, all while carrying its own power and computing onboard so it can operate completely untethered. It can execute a sequence of blind, vision-free keyboard commands while holding itself upright, and separately use overhead visual feedback to push objects toward specific target positions, with the whole simulation calibrated against real measurements taken from the physical hardware. The result is a mobile manipulator that carries no dedicated locomotion hardware at all, a hand that simply walks itself to the job, then gets straight to work with the same fingers it walked in on.