NO LEGS, NO WHEELS: Robot Hand Crawls Using Only Its Fingers
Gallery
Videos
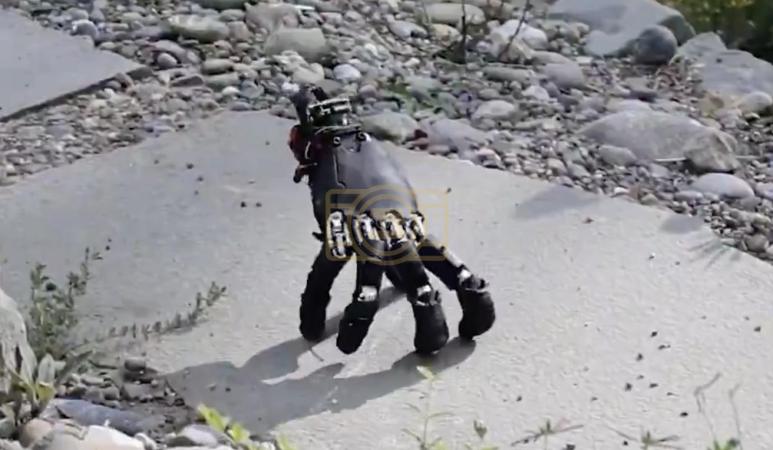
Researchers at ETH Zürich have built something straight out of a horror movie: a robotic hand that crawls across surfaces on its own fingers, with no wheels, no legs, and no separate drive system bolted underneath. The same fingers designed to grasp objects also bear the hand's full weight and carry it across the ground, essentially turning a grasping tool into its own means of transportation. The team did not build a special-purpose machine for this trick either. They kept the hand's existing finger design and position controller exactly as they were, then wrote an entirely new reward formulation suited to a hand's unique geometry, since standard quadruped locomotion research assumes four evenly spaced, identical legs, a layout that looks nothing like a palm with unevenly spaced fingers and a thumb that matches none of them.
That custom approach paid off, letting the hand move faster in simulation than it did using reward functions borrowed straight from quadruped robots. In testing, the hand crawls, steers, and even recovers on its own after being knocked over, all while carrying its own power and computing onboard so it can operate completely untethered. It can execute a sequence of blind, vision-free keyboard commands while holding itself upright, and separately use overhead visual feedback to push objects toward specific target positions, with the whole simulation calibrated against real measurements taken from the physical hardware. The result is a mobile manipulator that carries no dedicated locomotion hardware at all, a hand that simply walks itself to the job, then gets straight to work with the same fingers it walked in on.