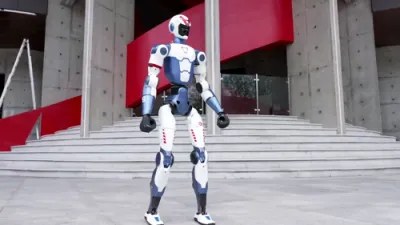
ROBOT ON WHEELS: Boston Dynamics Straps Scooter Wheels To Atlas Ankles In Bold Experiment
Boston Dynamics has put scooter wheels on its Atlas humanoid robot, and the reason is more serious than it looks. The company attached the wheels to Atlas's ankle actuators using a simple adapter, creating a research testbed to see how faithfully a reinforcement learning whole-body controller works with real motors. The goal is to find out how the controller behaves when those motors run at their torque and speed limits under continuous load, which is the kind of stress robots face outside the lab. A video shows the wheeled Atlas rolling smoothly, turning, skating backward and pulling off dynamic maneuvers in a warehouse.
One of the most interesting details is that the learned policy adapted on its own to the new hardware, using wheel steering for sideways movement instead of sliding its feet. The experiment is meant to help close the gap between simulation and reality, a long-standing problem for robots trained mostly in virtual environments. According to the company, what it learns about how the actuators behave will feed directly back into improving the standard bipedal Atlas. The work fits with Boston Dynamics' partnership with the RAI Institute, announced in February 2025, to use reinforcement learning to build dynamic and generalizable skills on the electric Atlas. The big questions now are how much of this will carry over to walking robots and whether wheels ever become more than a lab experiment.