ROBOTIC TRASH REVOLUTION: Revere Robotics Develops Autonomous Robot That Takes Your Trash Bins to the Curb
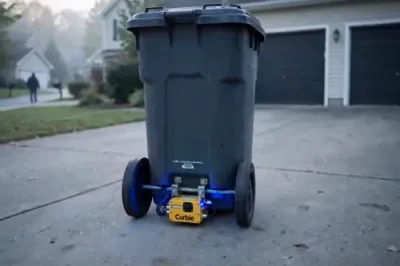
A Boston-based startup called Revere Robotics is developing an autonomous robot designed to handle one of the most routine household chores: taking trash bins to the curb and bringing them back after collection. Called Curbie, the device attaches directly to existing standard residential garbage bins, eliminating the need for homeowners to purchase a specially designed container. According to the company's development details, the robot is being designed to transport heavy bins weighing more than 100 pounds, with a reported target capacity of over 120 pounds, while moving at approximately walking speed. Its intended operation includes automatically delivering the bin to the curb on collection day and returning it to the property after pickup. The planned features also include all-weather capabilities to navigate rain, snow, and icy sidewalks, as well as a safety system that detects excessive tilting and stops the robot before sending an alert to the user.
Curbie remains an early-stage field prototype, and the promotional video accompanying the announcement features concept renders rather than footage demonstrating a fully operational product. Revere Robotics is also developing additional autonomous navigation features, including onboard perception technology and driveway geofencing intended to help the device recognize its operating area and avoid unsafe movements. These capabilities could make the robot particularly useful for households with long driveways, heavy garbage containers, or residents who have difficulty moving bins themselves. However, the technology will need to demonstrate reliable performance across different property layouts, weather conditions, and municipal collection arrangements before it can become a practical household appliance. The company has not yet announced official pricing or a confirmed commercial release date. If successfully developed, Curbie could introduce a new category of household automation by bringing robotic assistance to an ordinary weekly task that most homeowners still perform manually.